AdaPlanner: Adaptive Planning from Feedback with Language Models
Abstract
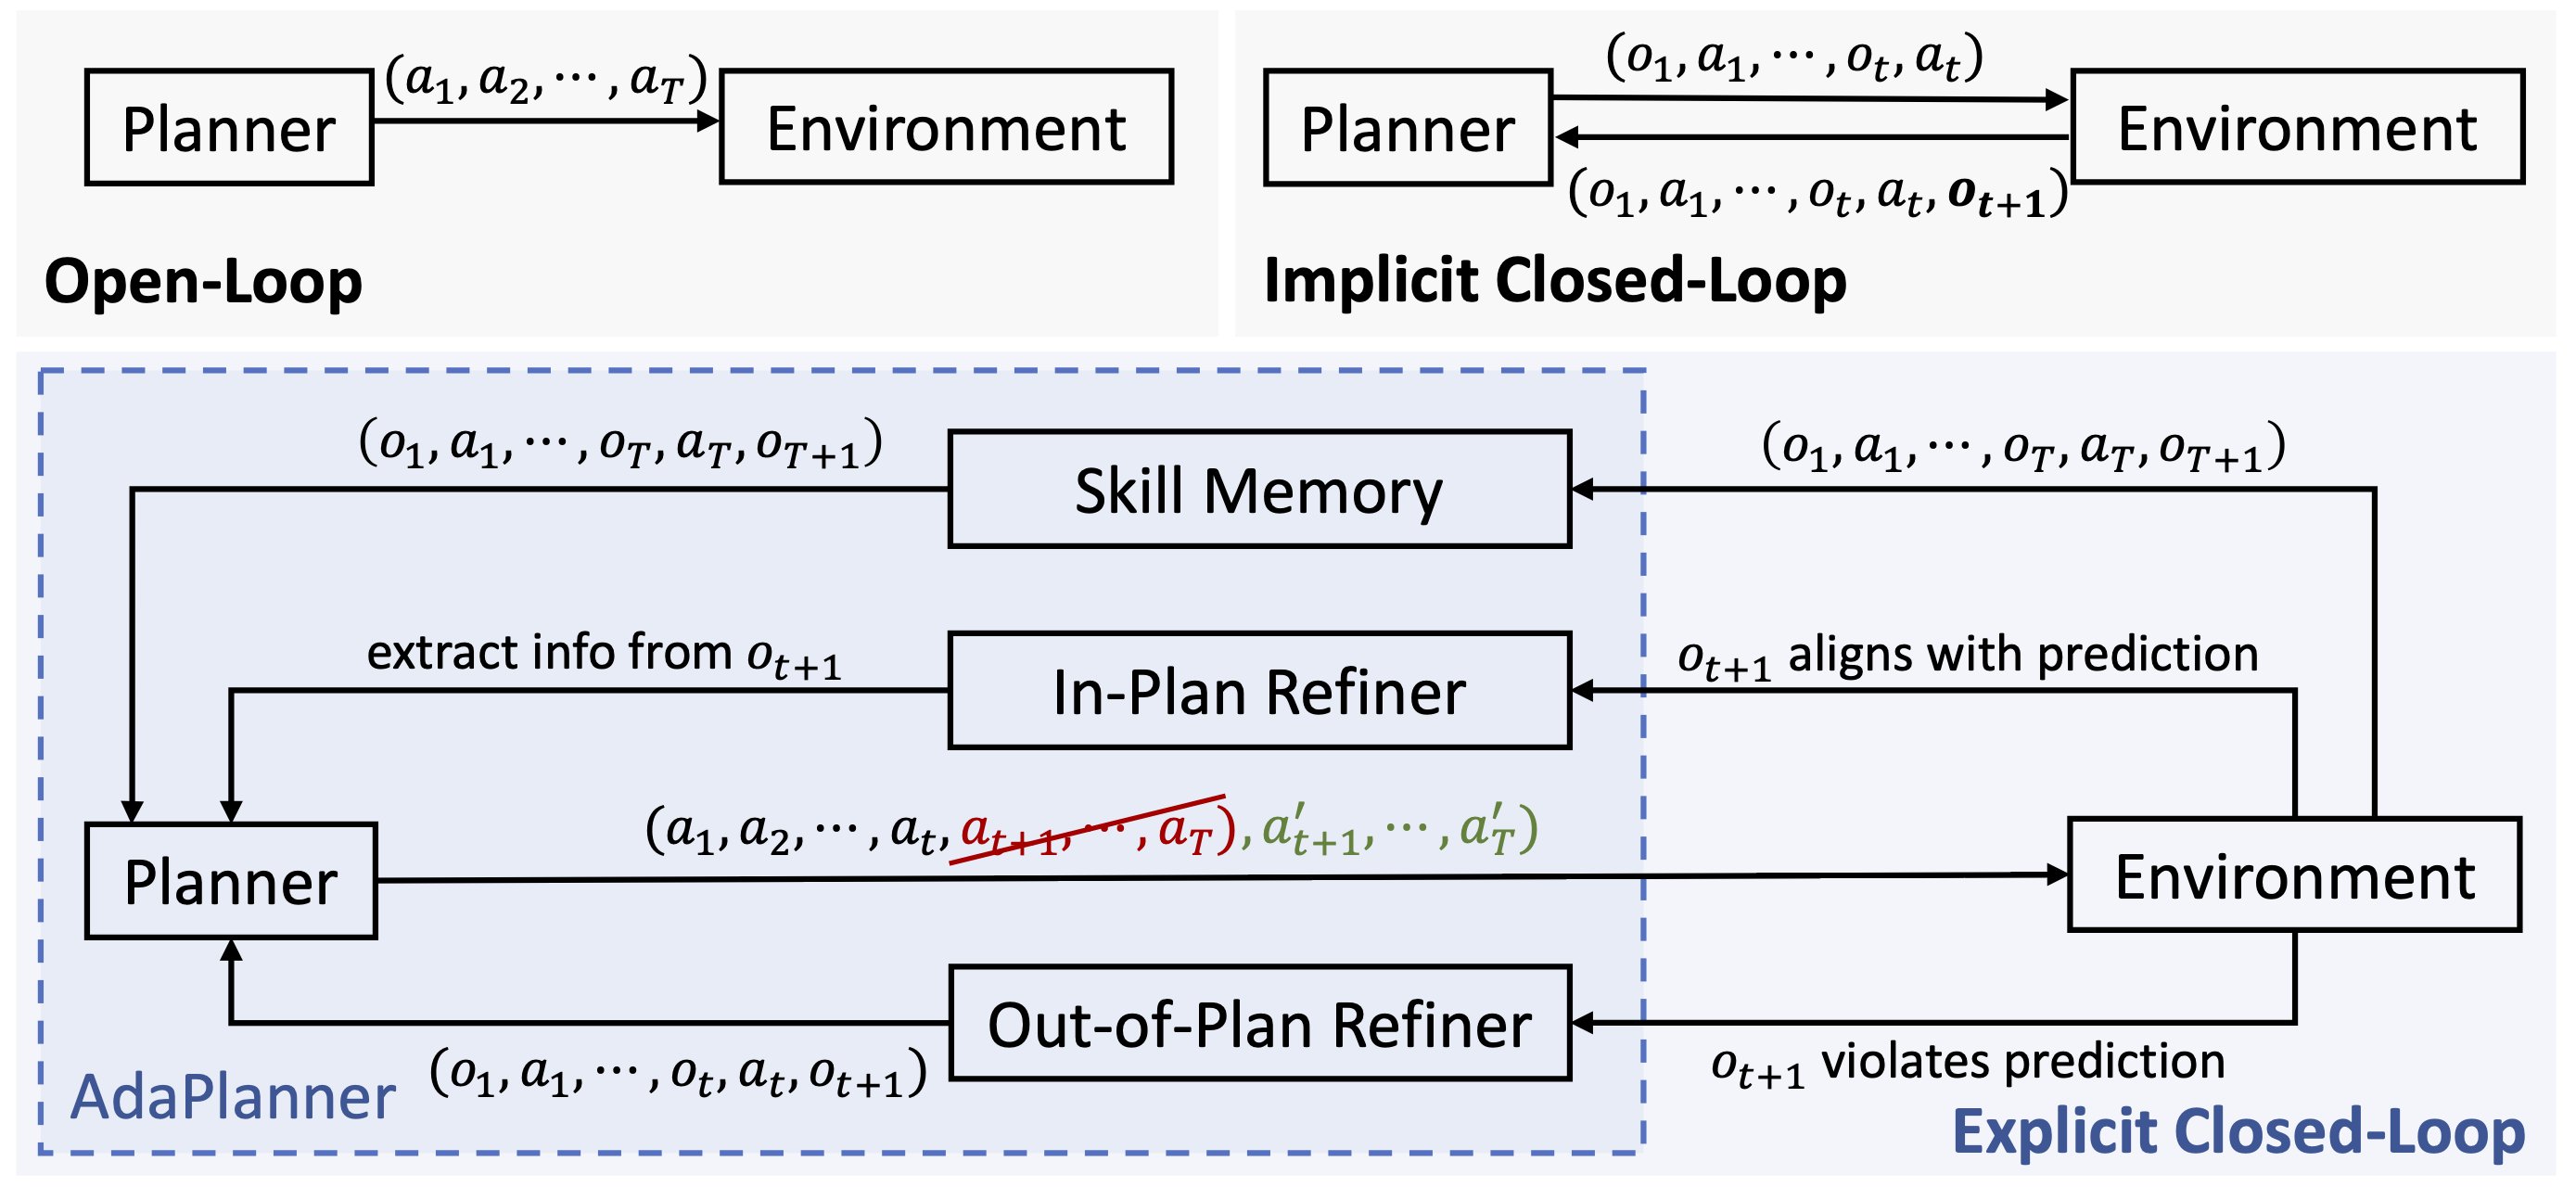
Large language models (LLMs) have recently demonstrated the potential in acting as autonomous agents for sequential decision-making tasks. However, most existing methods either take actions greedily without planning or rely on static plans that are not adaptable to environmental feedback. Consequently, the sequential decision-making performance of LLM agents degenerates with problem complexity and plan horizons increase. We propose a closed-loop approach, AdaPlanner, which allows the LLM agent to refine its self-generated plan adaptively in response to environmental feedback. In AdaPlanner, the LLM agent adaptively refines its plan from feedback with both in-plan and out-of-plan refinement strategies. To mitigate hallucination, we develop a code-style LLM prompt structure that facilitates plan generation across a variety of tasks, environments, and agent capabilities. Furthermore, we propose a skill discovery mechanism that leverages successful plans as few-shot exemplars, enabling the agent to plan and refine with fewer task demonstrations. Our experiments in the ALFWorld and MiniWoB++ environments demonstrate that AdaPlanner outperforms state-of-the-art baselines by 3.73% and 4.11% while utilizing 2x and 600x fewer samples, respectively.
Materials
BibTeX
@inproceedings{NEURIPS2023_b5c8c1c1,
 author = {Sun, Haotian and Zhuang, Yuchen and Kong, Lingkai and Dai, Bo and Zhang, Chao},
 booktitle = {Advances in Neural Information Processing Systems},
 doi = {10.52202/075280-2537},
 editor = {A. Oh and T. Naumann and A. Globerson and K. Saenko and M. Hardt and S. Levine},
 pages = {58202--58245},
 publisher = {Curran Associates, Inc.},
 title = {AdaPlanner: Adaptive Planning from Feedback with Language Models},
 url = {https://proceedings.neurips.cc/paper_files/paper/2023/file/b5c8c1c117618267944b2617add0a766-Paper-Conference.pdf},
 volume = {36},
 year = {2023}
}